
RB-Y1
RB-Y1
A mobile dual-arm robot platform designed for research.
- Research Platform
- SDK Provided
- GPU-Equipped
- Arm Payload
- 3 kg / 6.6 lb per arm
- Arm Reach
- 600 (to wrist) + hand [mm]
- Arm Repeatability
- ±0.05mm


a mobile dual-arm robot platform focused on research and expansion
RB-Y1
RB-Y1 is not a finished robot for a single task, but a humanoid-style mobile dual-arm robot platform for experimenting with and validating manipulation, mobility, and perception technologies in real physical environments. It serves as a base platform for next-generation robotics technologies such as AI-based manipulation learning, teleoperation, and whole-body control research.
Key Features
Key Features

Platform architecture integrating mobility and manipulation into one workflow
RB-Y1 is designed as a mobile dual-arm robot platform that treats mobility and manipulation as one integrated task rather than separate functions.
Stable wheel-based mobility, dual-arm manipulation, and whole-body control provide consistent control and stability in environments where precise work and movement are repeated.

Whole-body control based on redundant degrees of freedom
The RBY1 is a robot with 24 degrees of freedom (24 DOF) in the overall system configuration, including the neck, both arms, legs, and mobility.

Open control structure for optimal and impedance control
RB-Y1 does not prescribe a fixed control method. Its SDK-based open control environment allows researchers to design and verify optimal control, impedance control, and whole-body control structures, making it suitable for teleoperation, human-robot interaction, real-world manipulation, and AI learning research.

Software architecture for stability, safety, and expandability
RB-Y1 uses a dual-PC architecture that separates real-time control from user applications. The Robot PC handles physical motion and safety, while the User PC supports ROS 2, the RB-Y1 SDK, and user applications, allowing high-performance control and flexible algorithm development at the same time.

Drive reliability for repeated experiments and long operation
By applying actuator technology verified by cooperative robots and joint brake structure that maintains posture even when power is cut off, it maintains stable motion even in long experiments and repeated operation environments.
It is designed to enable reliable experiments in real physical environments beyond laboratory environments.

Research pipeline connecting simulation, teaching, and the robot
The RB-Y1 provides a consistent experimental environment for repeatedly conducting research, learning, and validation.
In a simulation environment using a URDF/MJCF/USD-based model, control algorithms and operational strategies can be pre-validated, and after collecting data for Learning from Demonstration (LfD) through leader arm or VR-based teaching, it can be applied to Silrobot using the same SDK interface.
Platform architecture integrating mobility and manipulation into one workflow
RB-Y1 is designed as a mobile dual-arm robot platform that treats mobility and manipulation as one integrated task rather than separate functions.
Stable wheel-based mobility, dual-arm manipulation, and whole-body control provide consistent control and stability in environments where precise work and movement are repeated.
Whole-body control based on redundant degrees of freedom
The RBY1 is a robot with 24 degrees of freedom (24 DOF) in the overall system configuration, including the neck, both arms, legs, and mobility.
Open control structure for optimal and impedance control
RB-Y1 does not prescribe a fixed control method. Its SDK-based open control environment allows researchers to design and verify optimal control, impedance control, and whole-body control structures, making it suitable for teleoperation, human-robot interaction, real-world manipulation, and AI learning research.
Software architecture for stability, safety, and expandability
RB-Y1 uses a dual-PC architecture that separates real-time control from user applications. The Robot PC handles physical motion and safety, while the User PC supports ROS 2, the RB-Y1 SDK, and user applications, allowing high-performance control and flexible algorithm development at the same time.
Drive reliability for repeated experiments and long operation
By applying actuator technology verified by cooperative robots and joint brake structure that maintains posture even when power is cut off, it maintains stable motion even in long experiments and repeated operation environments.
It is designed to enable reliable experiments in real physical environments beyond laboratory environments.
Research pipeline connecting simulation, teaching, and the robot
The RB-Y1 provides a consistent experimental environment for repeatedly conducting research, learning, and validation.
In a simulation environment using a URDF/MJCF/USD-based model, control algorithms and operational strategies can be pre-validated, and after collecting data for Learning from Demonstration (LfD) through leader arm or VR-based teaching, it can be applied to Silrobot using the same SDK interface.
Specifications
| Dimensions | 600 x 690 x 1,400mm (W x D x H) | ||||||||||||||||||
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
| Arm Payload | 3 kg per arm | ||||||||||||||||||
| Arm Reach | 600 (to wrist) + hand [mm] | ||||||||||||||||||
| Joint Range of Motion | Ankle roll120°/s-15° ~ 15°Ankle pitch120°/s-30° ~ 90°Knee180°/s-150° ~ 90°Hip pitch180°/s-45° ~ 90°Hip roll180°/s-30° ~ 30°Hip yaw180°/s-135° ~ 135°Shoulder pitch180°/s-180° ~ 180°Shoulder roll180°/s0° ~ 180°Shoulder yaw180°/s-180° ~ 180°Elbow pitch180°/s-150° ~ 0°Wrist yaw1 (1,2)360°/s-180° ~ 180°Wrist pitch (1,2)360°/s-90° ~ 110°Wrist yaw2 (1,2)360°/s-155° ~ 155°Wrist yaw (1,3)360°/s-180° ~ 180°Wrist pitch (1,3)360°/s-50° ~ 50°Wrist roll (1,3)120°/s-90° ~ 90° | ||||||||||||||||||
| Power Specification | 48 VDC | ||||||||||||||||||
| Operating Temperature | 40°C | ||||||||||||||||||
| Safety Functions | Low Level Controller (Motor Controller)- Position Reference Continuity Error- Position Tracking Error- Temperature Error- Overcurrent Error- Communication ErrorHigh Level Controller- Current Limit | ||||||||||||||||||
| Arm Repeatability(Based on collaborative robots) | ±0.05mm | ||||||||||||||||||
| Exterior Material | Aluminum | ||||||||||||||||||
| Driving Speed | 1.5m/s | ||||||||||||||||||
| Degrees of Freedom |
|
||||||||||||||||||
| Weight |
|
||||||||||||||||||
| Battery Capacity |
|
Collecting operation and learning data through devices
Collect Manipulation and Learning Data Through Devices
Leader Arm Series
The Leader Arm Series is a teleoperation and manipulation interface designed to directly transfer human manipulation motions to a robot and efficiently collect motion data required for machine learning research such as Learning from Demonstration (LfD).
When connected with the RBY Series, it can be used to build data-collection environments for manipulation research, remote control, and AI learning.
Leader Arm
#Reverse DirectionA basic manipulation and learning device for the RBY Series. It enables intuitive manipulation for behavior data collection and teleoperation-based research.

- Size
- 600 x 690 x 1,400mm (W x D x H)
- Degrees of Freedom
- Total: 14 DoF
Shoulder: 3 DoF x 2
Elbow: 1 DoF x 2
Wrist: 3 DoF x 2 - Weight
- 3.86kg
- Operating Range
- Shoulder pitch -360deg ~ 360deg
Shoulder roll -146deg ~ 8deg
Shoulder yaw -155deg ~ 155deg
Elbow -180deg ~ 6deg
Wrist yaw1 -155deg ~ 155deg
Wrist pitch -137deg ~ 123deg
Wrist yaw2 -155deg ~ 155deg - Actuator
- Shoulder: XM540-W150-R
Others: XM430-W120-R - Input Voltage
- 12 VDC
- Interface
- RS-485
* Specifications may change to improve performance.

Stand Leader Arm
#Forward DirectionFixed to a stand, this configuration provides a stable operating environment for long experiments and repeated manipulation. It is suitable for research that requires precise control setup, repeated experiments, data comparison, and validation because it can maintain a consistent posture and reference coordinates.

- Size
- W 850 mm
- Size
- D 610 mm
- Size
- H 1420 ~ 2070 mm
(stroke : 650 mm) - Weight
- Stand Weight 14.9 kg
Total Weight (Including Leader Arm Modules) 18.5 kg - Features
- Guide Rail Stroke 0 ~ 150 mm
Guide Rail Precision 1 mm/rev
Mobile Wheel 1.5 inch wheel (brake type)

- Weight
- 3.6 kg
- Degrees of Freedom
- 14 DOF
- Range of Motion
- Right Arm
- Shoulder Pitch -180° ~ +180°
- Shoulder Roll -135° ~ +15°
- Shoulder Yaw -155° ~ +155°
- Elbow Pitch -175° ~ 0°
- Wrist Yaw1 -155° ~ +155°
- Wrist Pitch -120° ~ +140°
- Wrist Yaw2 -155° ~ +155°
Left Arm
- Shoulder Pitch -180° ~ +180°
- Shoulder Roll -15° ~ +135°
- Shoulder Yaw -155° ~ +155°
- Elbow Pitch 0° ~ +175°
- Wrist Yaw1 -155° ~ +155°
- Wrist Pitch -140° ~ +120°
- Wrist Yaw2 -155° ~ +155° - Actuator
- Dynamixel
- Power Requirement
- 12 VDC
- Interface
- RS-485
- Features
- Height adjustment: Yes
Arm angle adjustment: Yes
Arm length adjustment: Yes

Neck Joint Module
A module for human-like gaze movement and head motion.
| Spec | Value |
|---|---|
| Size | 122.5 x 70.5 x 194 mm |
| Weight | 1.5 kg |
| Output stage material | AL6061 |
| Nominal torque | 5.4 Nm |
| Max. intermittent torque | 30 Nm |
| Starting Torque | <= 2.8 Ncm |
| Angle transmission accuracy | <= 1.5 arcmin |
| Hysteresis loss | <= 2 arcmin |
| Nominal Rotational speed | 20 rpm |
| Max. Rotational speed | 30 rpm |
| Maximum Allowable Moment (Based on Cross Bearing) |
46.4 Nm |
| Module Degrees of Freedom and Range of Motion (Counterclockwise +) |
YAW(-90°+90°) Pitch(-90°+90°) |
| Encoder resolution | 14bit |
With a variety of options to flexibly expand mobility, manipulation, and interfaces, RB-Y is not a single robot, but rather a robot platform that implements different scenarios.

Gripper
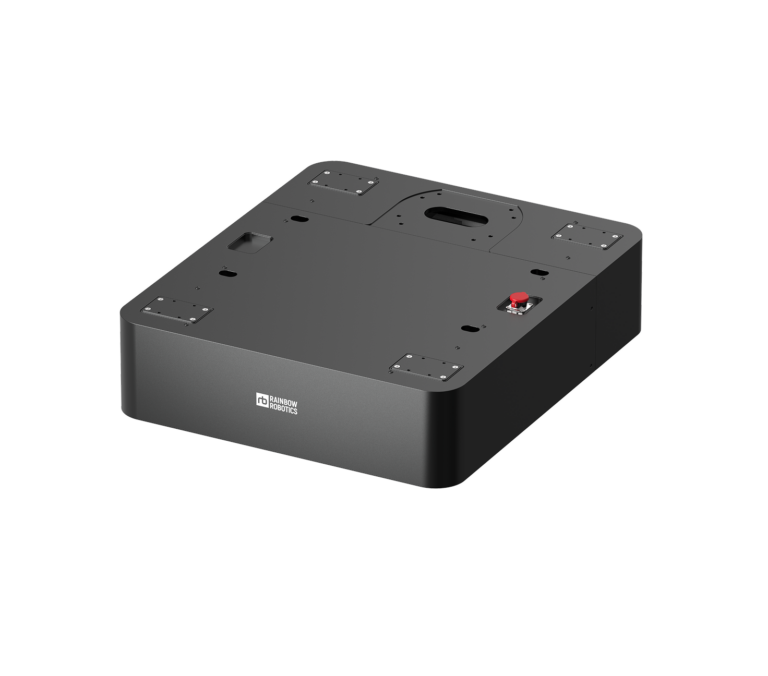
Mobile Wheels

Tele-Op VR Device

Touch Pad & Joystick
Y1 Module Configuration VersionV1.2 vs V1.3
*Basic option
Talk Precision Teaching: V1.2, V1.3
D-Bounce Mobile Base: V1.2
Meganix Mobile Base: V1.2, V1.3
*Vision sensor bracket provided
*The vision camera is not provided.
| Version | V 1.2 | V 1.3 |
|---|---|---|
| Direction | Precision-oriented manipulation performance | Manipulation and flexibility-oriented (VR integration) |
| Recommended Applications | Precision manipulation and repetitive tasks | Teleoperation, research, and AI training |
| Wrist Configuration | YPY (Yaw-Pitch-Yaw) inline type — linear motion or single-axis rotation | YPR (Yaw-Pitch-Roll) ball-joint type — multidirectional rotation about a single point |
| Manipulation Characteristics | High positional and orientation accuracy; well suited to consistent repetitive manipulation | Greater freedom in posture changes and a human wrist-like manipulation feel; well suited to VR-based teleoperation |
| Features | Axis configuration commonly used in collaborative and industrial robots | Axis configuration commonly used in human-like humanoid robots |
| Workability | May result in unnecessary motion in certain tasks | Three independent axes enable human-like motion |
| Teachability | Different human and robot axis configurations; leader-arm operation is easy | Same axis configuration as humans; well suited to teleoperation |
| Controllability | Wrist singularities occur near the home pose. In a Y-P-Y wrist, singularities between the Y axes make control complex. | Wrist singularities occur near the home pose. In a Y-P-R wrist, each axis is independent, making control relatively simple. |
| Configuration | RB-Y1 main body, dual-arm built-in FT sensors, Neck Joint Module (optional), gripper (optional) | RB-Y1 main body, Neck Joint Module (optional), gripper (optional) |
*Default options may vary by module configuration version.
Please contact us for details.
Download
Downloads
| Select | Product | Resource type | Resource details | Download link |
|---|---|---|---|---|
| RB-Y1 Mobile Humanoid | Drawing | RB-Y1 _ver1.0 2D Drawings Drawing | ||
| Drawing | RB-Y1 _ver1.0 for Differential gear typed Mobile Drawing | |||
| Drawing | RB-Y1 _ver1.0 for Mecanum wheel typed Mobile Drawing | |||
| Drawing | RB-Y1 _ver1.1 for Differential gear typed Mobile Drawing | |||
| Drawing | RB-Y1 _ver1.1 for Mecanum wheel typed Mobile Drawing | |||
| Drawing | RB-Y1 _ver1.2 for Differential gear typed Mobile Drawing | |||
| Drawing | RB-Y1 _ver1.2 for Mecanum wheel typed Mobile Drawing | |||
| Catalog | RB-Y1 Catalog Catalog |
RB-Y1 _ver1.0 2D Drawings
DrawingRB-Y1 _ver1.0 for Differential gear typed Mobile
DrawingRB-Y1 _ver1.0 for Mecanum wheel typed Mobile
DrawingRB-Y1 _ver1.1 for Differential gear typed Mobile
DrawingRB-Y1 _ver1.1 for Mecanum wheel typed Mobile
DrawingRB-Y1 _ver1.2 for Differential gear typed Mobile
DrawingRB-Y1 _ver1.2 for Mecanum wheel typed Mobile
DrawingA proven automation partner across diverse industries
- Education·Research
- Semiconductors·Electronics
- the automobile industry
A proven automation partner across diverse industries


