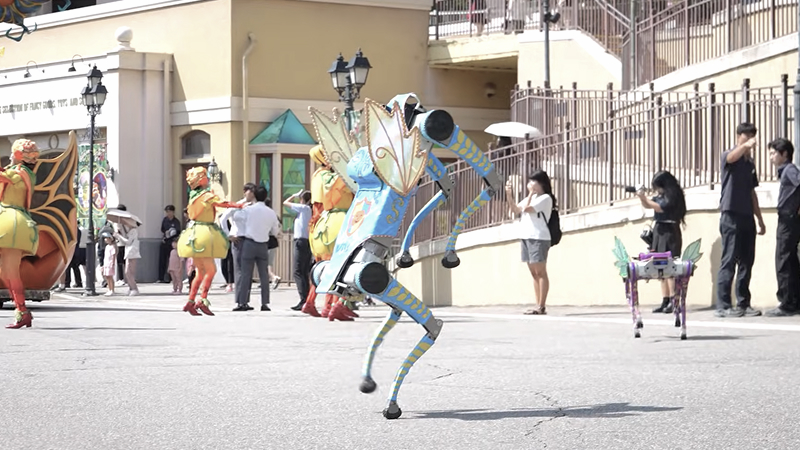
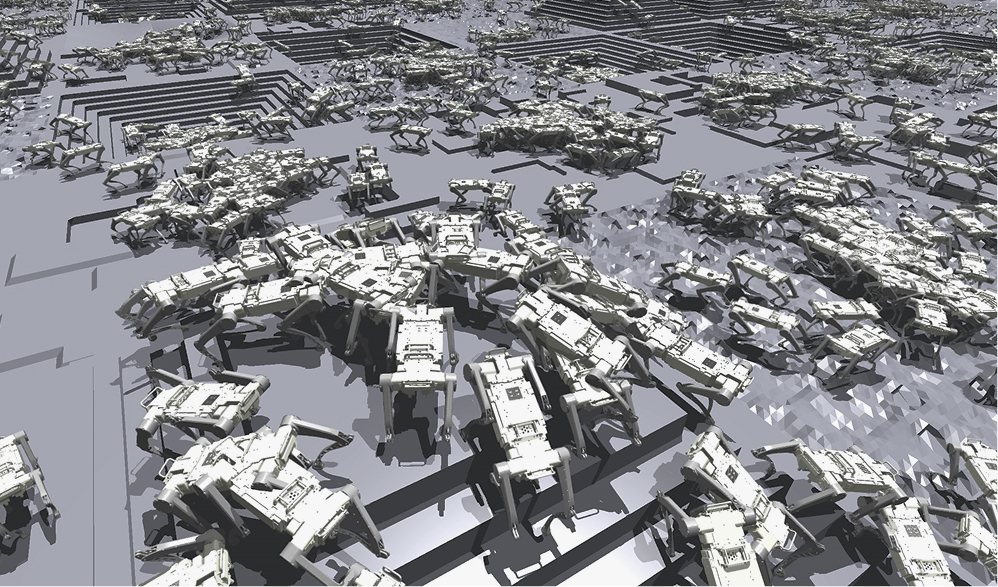
Parallel operation with reinforcement-learning-based walking
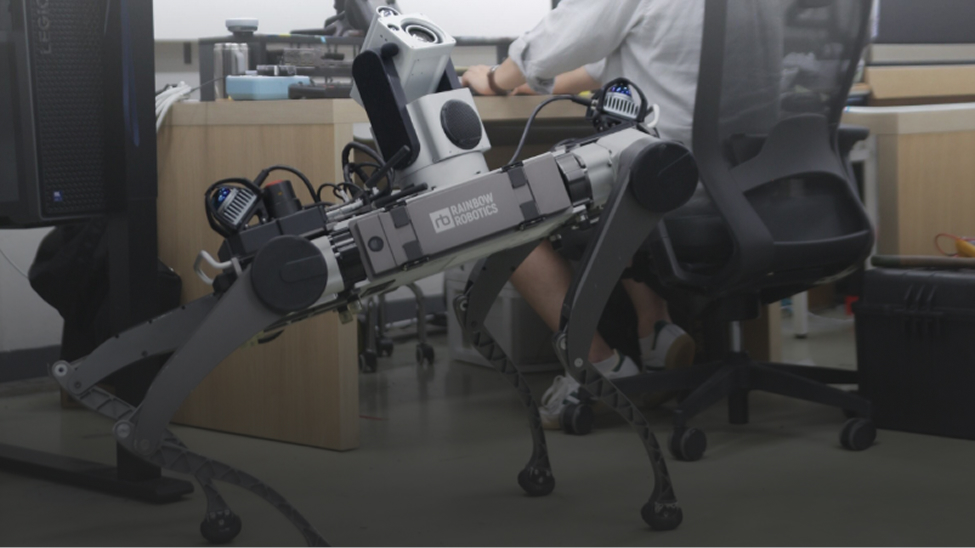
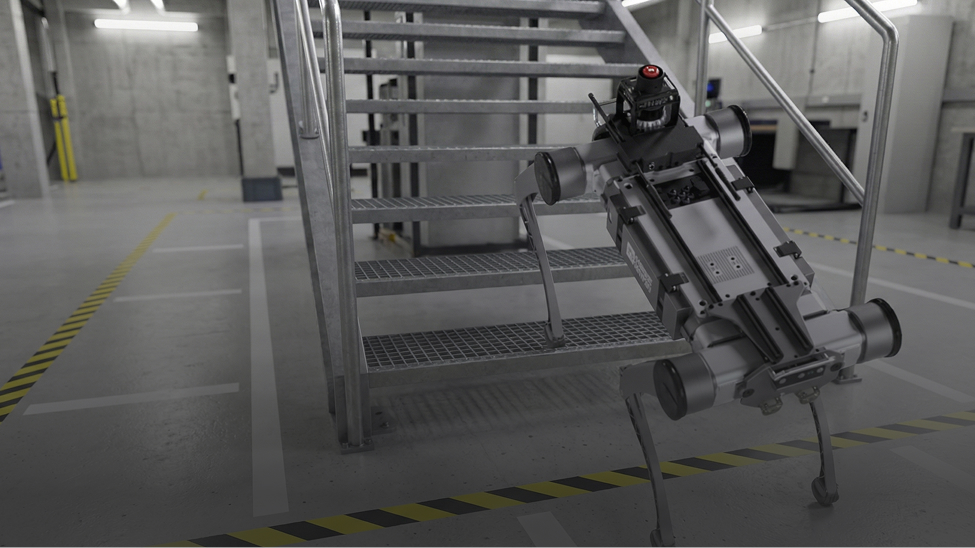
RBQ combines dynamics-based walking control and AI gait technology to walk stably on unstructured terrain such as stairs, slopes, and uneven surfaces.
Quadruped Robot
An AI-based high-mobility quadruped robot platform for rough and unstructured terrain.
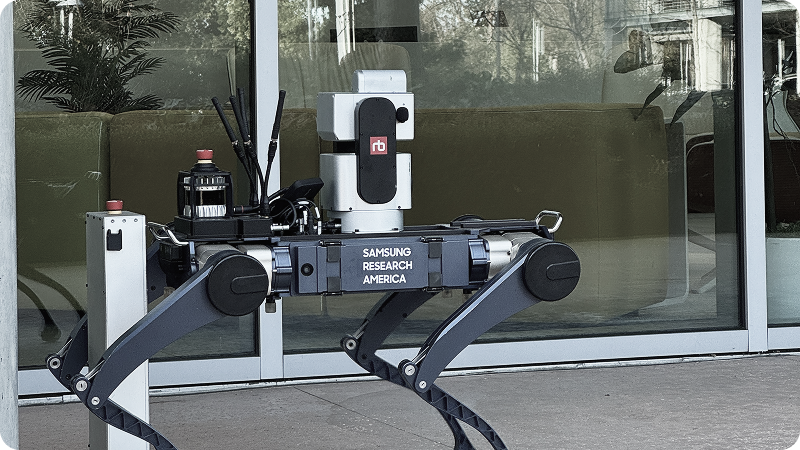
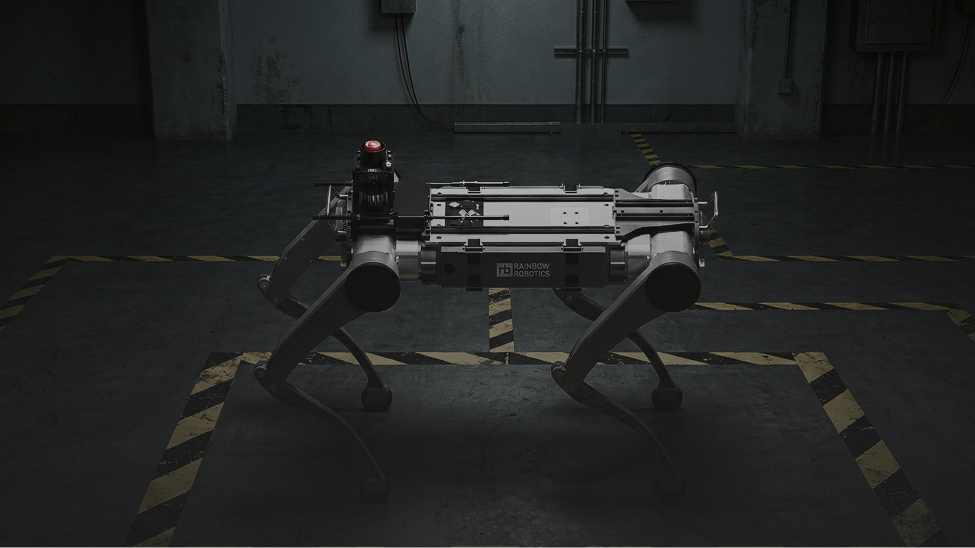
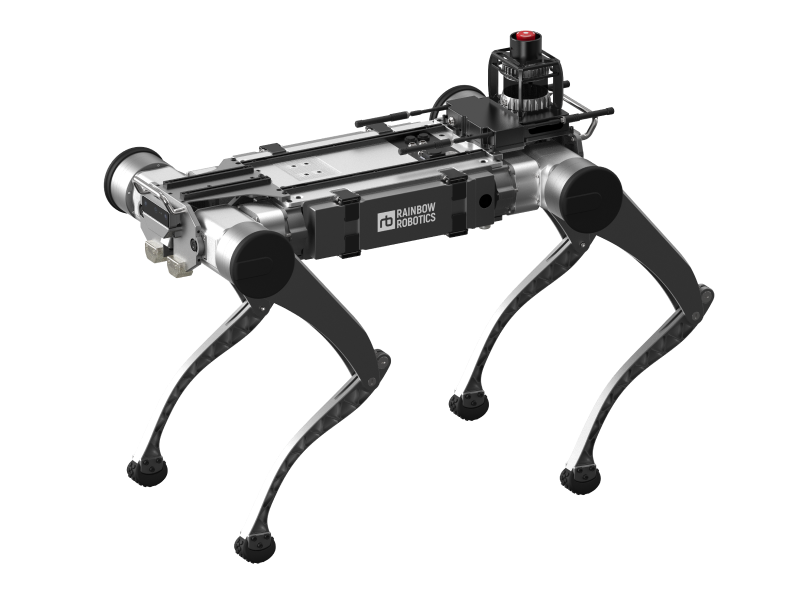
The RBQ Series is a quadruped robot platform designed for stable movement across rough terrain, slopes, stairs, and other unstructured environments by applying dynamics-based walking control and AI gait technology.
Based on walking stability and system architecture validated through research and field demonstrations, it can be used for site-centered missions such as patrol, inspection, and safety management,
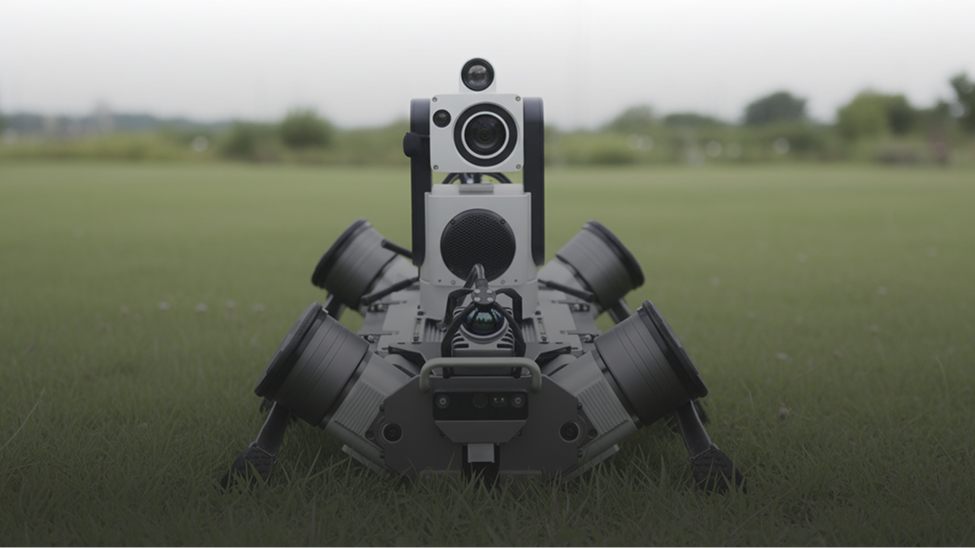
and can be configured flexibly for target environments through sensor and module expansion.
The RBQ Series is a quadruped robot platform lineup that can be selected according to application environment and purpose.
A quadruped robot platform designed for outdoor walking and sensor expansion
RBQ-10
A legged-wheel hybrid quadruped robot platform combining legs and wheels
RBQ-10W
RBQ combines dynamics-based walking control and AI gait technology to walk stably on unstructured terrain such as stairs, slopes, and uneven surfaces.
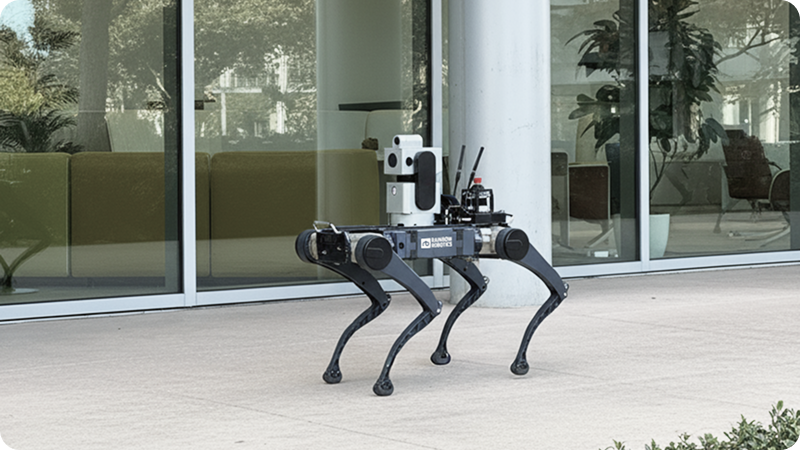
As a quadruped robot platform applicable to patrol, inspection, safety management, and other scenarios in environments that are difficult for people to access,
RBQ continues to expand its range of use.
Surveillance and patrol
Rough-terrain autonomous mobility
Facility inspection
Remote-operation field intervention